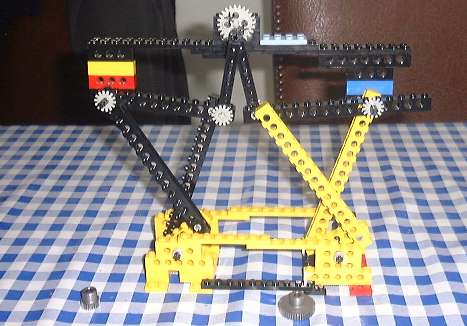
 The above picture shows Jimmys prototype leg made
from Lego. The foot moves backward and frowards and the lever system
keeps the foot at a constant height/level. The gear at the top
is acting as a simple crank which moves the foot up and down.
The cranks rise and fall is reduced by the lever system. The
reduction of the foot's rise and fall is a ratio of the bottom
connecting rod and the the top connecting rod of the X. For the
final version of Jimmy we had the crank rise and fall at about
6mm which gave the foot rise and fall of about 2mm.
The Bare Chassis
|
